
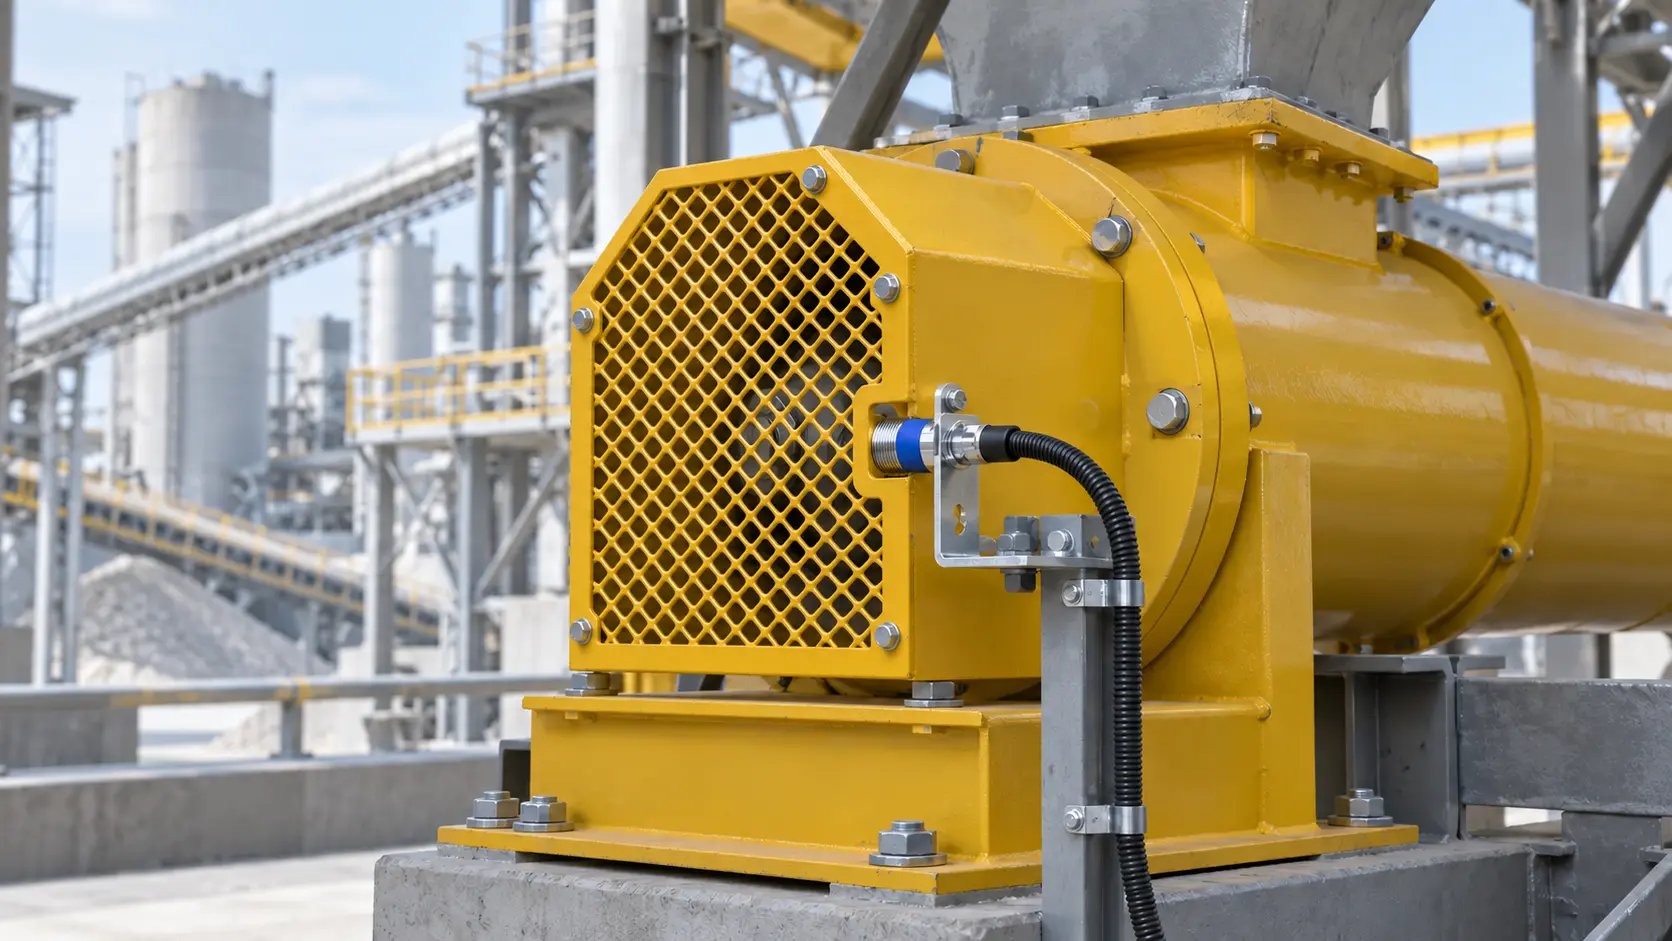
A cement screw conveyor zero-speed switch should confirm that the screw—or the last shaft whose rotation proves screw movement—is actually turning. A PLC run bit, energized contactor, or VFD frequency command only proves that a command was issued. It cannot by itself detect a broken coupling, missing key, stalled screw, or failed transmission between the monitored point and the flight shaft.
The VOGO tubular cement conveyor range can be configured around project duty, geometry, drive, and interfaces. Its published product information does not state that a zero-speed switch, safety-rated monitor, target assembly, or control panel is standard supply. Put those requirements in the enquiry, drawing, I/O list, and acceptance test if the project needs them.
This guide covers process monitoring and equipment protection. It does not certify a personnel-safety function or prescribe one universal trip speed.
Cement screw conveyor zero-speed switch purpose
The useful question is not “Is the motor powered?” but “Is material-moving hardware rotating at an acceptable speed?” A shaft sensor can detect complete stoppage, and an underspeed monitor can act before speed reaches zero. The correct function depends on the failure that the plant must detect.
Examples include stopping upstream feed when the screw slows, alarming before a downstream blockage fills the inlet, or preventing an automatic restart sequence from proceeding without motion proof. The cement screw conveyor VFD control guide covers the wider permissive and trip structure; the speed switch supplies one independent field signal within that logic.
Write the cause-and-effect requirement first:
| Detected condition | Required control response | Reset condition to define |
|---|---|---|
| No pulses after a start command and startup delay | Stop the screw and isolate upstream material feed | Manual investigation or defined automatic retry |
| Speed below the permitted band while running | Alarm, then trip if the condition persists | Speed restored and fault acknowledged |
| Sensor circuit or power fails | Defined fault response; fail-safe behavior depends on the selected circuit | Electrical fault cleared and tested |
| Screw stops after a normal stop command | Confirm coast-down for sequencing only | Next-start permissive as designed |
Do not copy these responses into a safety PLC without a risk assessment. They are a process-control template, not a safety integrity claim.
Monitor the shaft that proves screw rotation
Place the sensing point after the failure modes you want to detect. A sensor on the motor fan or reducer input can continue reporting rotation when a coupling, output key, chain, or screw connection has failed. Monitoring a tail shaft or another mechanically linked shaft at the far end can provide stronger proof that the driven assembly is moving, provided the exact conveyor construction makes that point representative.
The mounting arrangement must keep the target, sensor, bracket, and wiring clear of rotating hazards. 4B’s guarded shaft sensor mount is one first-party example of a target and sensor moving with the shaft support while remaining guarded. Its dimensions, target count, attachment method, speed limit, and sensor compatibility are product-specific; they are not generic values for every screw conveyor.
An inductive device detects a passing metal target. Confirm the target material, size, sensing face, air gap, shaft runout, bracket stiffness, temperature, ingress protection, hazardous-area classification, supply voltage, output type, and cable route against the chosen manual. A fabricated bolt head may produce a signal, but it still needs a secure, balanced, guarded installation and a repeatable gap throughout a revolution.
Do not aim the sensor at a motor shaft merely because access is easier. If the project cannot monitor a mechanically representative point safely, document what failures remain undetected.
Calculate pulse rate at minimum operating speed
Sensor selection begins at the lowest approved shaft speed, not only the nominal motor speed. For a target wheel or guarded shaft target:
Pulse rate (pulses/min) = shaft speed (rpm) × targets per revolution
Consider a hypothetical screw that normally runs at 28 rpm and may be commanded down to 8 rpm. With four targets per revolution:
- At 28 rpm: 28 × 4 = 112 pulses/min, so one pulse arrives about every 0.536 seconds.
- At 8 rpm: 8 × 4 = 32 pulses/min, so one pulse arrives every 1.875 seconds.
These figures are an example, not VOGO operating data. They show why a one-second “no pulse” timer would nuisance-trip at the stated minimum speed even when the shaft is healthy. The monitor must accept the full pulse-rate range, and its dropout or missing-pulse logic must allow the longest legitimate interval plus the agreed tolerance.
More targets shorten the time between pulses and may improve low-speed response, but only within the sensor’s frequency range and target-spacing requirements. Excess targets, poor geometry, eccentricity, or an incorrect sensing gap can create double pulses or missed pulses. Verify the actual waveform or pulse count during commissioning rather than relying only on calculated values.
The 4B M800 Elite product information illustrates a self-contained inductive monitor calibrated to normal shaft speed with product-specific alarm, shutdown, pulse-range, and startup-delay options. Those published settings describe that model. Another device may use an absolute rpm threshold, percentage underspeed, missing-pulse timer, or analog speed output.
Set startup bypass and trip timing from evidence
A conveyor needs time to accelerate before stable pulses are available. The startup bypass should exceed the measured worst-case time from an accepted start command to valid motion at the monitored shaft, including contactor or VFD enable, brake release if applicable, mechanical acceleration, and input filtering. Add only the justified margin from repeatable tests.
A bypass that is too short creates nuisance trips. One that is too long permits material to enter a stationary screw and can hide a failed start. The 4B SR1V5 speed relay manual shows a product-specific start-delay input; it is evidence that startup timing is an explicit function, not authority for using its illustrated duration on every machine.
For running underspeed, compare the threshold with every approved VFD setpoint. If the sensor is calibrated at full speed and trips at a fixed percentage below that value, an intentional low-speed command may look like a fault. Options include a monitor designed for the complete speed range, speed-dependent PLC logic with appropriate integrity, or a fixed threshold below the minimum permitted process speed. The controls engineer must evaluate response time, signal failure, unauthorized setting changes, and the consequences of a false negative.
Keep delay stages visible. Separate input filtering, missing-pulse time, alarm delay, shutdown delay, PLC scan time, output relay time, VFD stop response, and mechanical coast-down. A single setting labelled “delay” should not conceal the total time from a real slowdown to stopped upstream feed.
Connect the trip to the material-flow sequence
When a screw slows or stops, continuing upstream flow can fill the inlet, compact cement, or overload the next restart. The normal protective sequence is project-specific, but it commonly needs to stop or close the upstream feed source before material accumulates further, stop the affected drive, latch a meaningful fault, and block restart until the defined conditions are restored.
For a screw mounted directly under a hopper, bin, or silo with a continuously flood-loaded inlet, call the equipment a screw feeder. Do not apply a control-fed conveyor capacity table to that inlet. Withdrawal may require increasing or variable pitch, tapered outside diameter, or a mass-flow design; reduced pitch alone is not a complete answer. The silo discharge screw feeder design guide covers head load, full-load starting torque, VFD low-speed torque, reducer service factor, and stall protection.
A zero-speed switch reports motion; it does not solve arching, rat-holing, or bridging. Investigate silo geometry, outlet size, cement moisture and consolidation, aeration or other flow aids, isolation-valve position, and feeder inlet design. Likewise, an enclosed housing is not automatically airtight, dust-free, or pressure rated. Sensor penetrations, seals, cable entries, casing joints, and the actual positive or negative pressure duty need an approved containment design.
Keep process monitoring separate from personnel safety
A general-purpose zero-speed or underspeed switch must not be assumed to prove a safe standstill for opening a guard. Rockwell Automation’s Safe Speed Monitor reference manual shows that a safety-rated speed function involves specified hardware, safety performance limits, sensor and actuator validation, system risk assessment, configuration control, and proof testing. A basic proximity sensor connected to a standard PLC does not acquire those properties by being labelled “zero speed.”
HSE’s machinery safety guidance places fixed guards first where practical and calls for isolation or lock-off before blockage removal, cleaning, or adjustment. Follow the applicable jurisdiction and site procedure. OSHA’s hazardous-energy guidance likewise addresses preventing unexpected energization or release of stored energy during servicing.
No pulse signal proves only what the validated circuit is designed to prove. It does not demonstrate electrical isolation, prevent gravity-driven material movement, relieve pneumatic pressure, or remove stored torsional energy. Apply lockout/tagout and verify the full energy boundary before accessing the conveyor.
Proof-test the complete monitoring chain
Commissioning should prove the sensor, wiring, logic, outputs, and process response—not merely that an LED flashes. Use an approved test method that does not require an exposed rotating target. A compatible pulse simulator, manufacturer test accessory, or controlled stopped-shaft test may be suitable depending on the design and site procedure.
Record these acceptance steps:
- Confirm the as-built sensing shaft, target count, target material, gap, guard, cable, terminal, and drawing references.
- Measure actual pulse rate at minimum, normal, and maximum approved speeds, unloaded and at the required representative load.
- Measure start-command-to-valid-pulse time and confirm the startup bypass against the slowest acceptable start.
- Simulate or create an approved underspeed/no-motion condition and record alarm time, trip time, upstream-feed response, drive stop, and fault message.
- Test loss of sensor power, broken or disconnected signal where safe, and the configured fail-safe response.
- Verify latching, reset authority, restart permissives, event history, and behavior after controller or site power restoration.
- Confirm that intentional VFD operation throughout the approved speed range does not generate a false trip.
- Record who witnessed the test, instrument or simulator identification, results, deviations, and corrective actions.
If reverse rotation must be detected, state it separately. A single pulse train from one proximity target normally proves pulse frequency, not direction. Direction detection may require an encoder or a suitable multi-channel arrangement and corresponding logic.
Conclusion
A cement screw conveyor zero-speed switch is useful only when its sensing point proves screw rotation, its pulse range covers the lowest approved speed, and its startup and trip delays are supported by measured timing. Proof-test the entire alarm and shutdown path, and never treat a process switch as a substitute for guarding, energy isolation, or a validated safety-rated standstill function. For a VOGO application review, provide the layout, shaft-speed range, drive sequence, required fault response, and monitoring scope.