
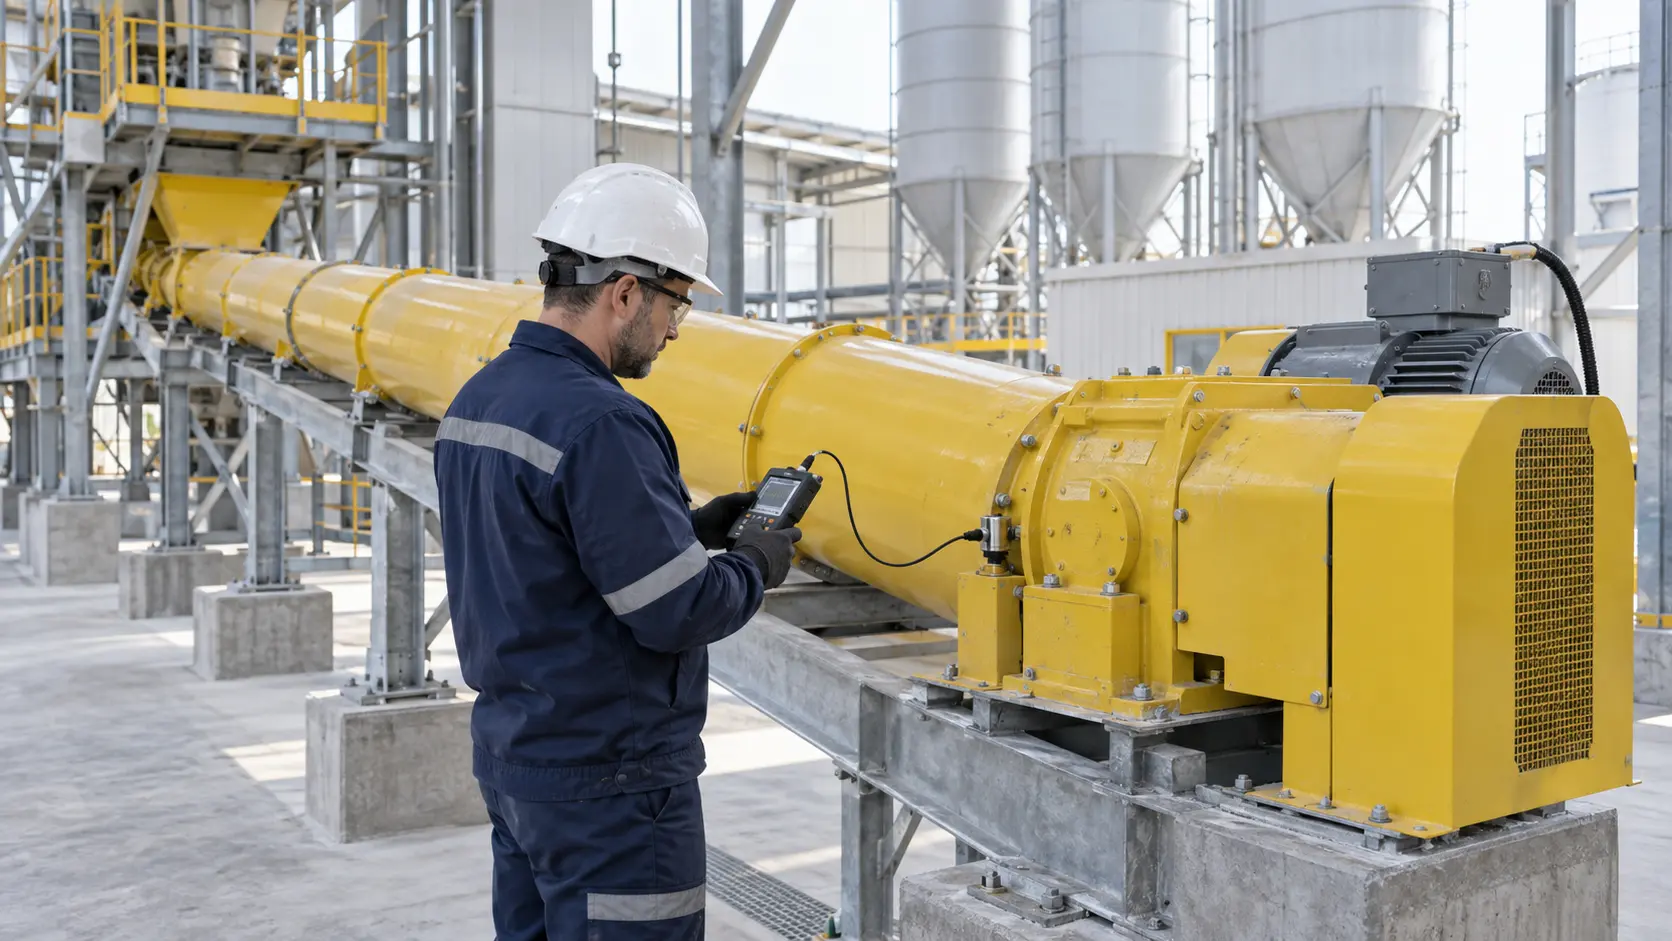
Cement screw conveyor vibration troubleshooting should begin with repeatable measurements, not a guessed “normal” value. Record the vibration on stationary bearing and gearbox housings at the same speed, load, temperature, sensor location, and direction. Compare the result with the machine’s healthy baseline, spectrum, current, noise, and process condition. Stop immediately if a sudden increase is accompanied by impact noise, casing contact, overheating, a loose support, or a current surge.
The VOGO tubular cement conveyor range is configured for the stated material, layout, duty, and interfaces of each project. Its published data does not provide a universal vibration limit, monitoring package, bearing alarm, or diagnostic result. Those requirements must be defined for the installed motor, reducer, conveyor, supports, and operating range.
This guide explains how to collect useful evidence and narrow the fault. It does not replace the motor, reducer, bearing, sensor, or site safety instructions.
Cement screw conveyor vibration troubleshooting starts with risk
Do not continue running a machine simply to obtain a cleaner trend when the condition may cause mechanical failure. Stop upstream flow and use the approved shutdown if vibration appears suddenly or is combined with metal impact, a new rubbing sound, smoke, rapid temperature rise, structural movement, loose fasteners, abnormal current, or loss of speed.
Before opening a guard, inspection cover, or casing, isolate every relevant energy source and control stored material. HSE’s machinery safety guidance calls for equipment to be switched off, isolated, or locked off before blockage removal, cleaning, or adjustment. A stopped motor, VFD stop command, or zero-speed indication is not by itself an isolation.
Classify the process connection before diagnosing load:
| Inlet condition | Correct equipment function | Vibration implication |
|---|---|---|
| Valve or separate feeder meters material into the screw | Control-fed screw conveyor | Compare empty and controlled-load readings at known rates |
| Hopper, bin, or silo remains continuously open to the inlet | Flood-loaded screw feeder | Include head load, withdrawal pattern, loaded starting torque, and consolidation |
| Flow is intermittent or surging | Unstable upstream feed or vessel discharge | Correlate vibration, current, speed, and material rate over time |
A flood-loaded inlet is feeder duty. It may require increasing or variable pitch, tapered outside diameter, or a mass-flow withdrawal design, plus checks for VFD low-speed torque, reducer service factor, and stall protection. A normal control-fed capacity table cannot describe that load.
Vibration monitoring also cannot solve arching, rat-holing, or bridging in the silo. Those conditions involve hopper geometry, outlet size, wall friction, moisture, compaction, consolidation, and flow aids as well as feeder withdrawal.
Build a repeatable measurement route
The same machine can produce different readings when the probe moves only a short distance or changes orientation. The SKF QuickCollect manual advises measuring under normal operating conditions, using a flat surface in the bearing load zone where possible, and keeping sensor position, angle, contact, and sensor type consistent.
Create an asset drawing with permanent point IDs. A practical route can include:
- motor non-drive-end and drive-end bearing housings;
- gearbox input and output bearing regions identified by its manufacturer;
- conveyor drive-end and tail-end bearing housings;
- accessible stationary structure beside an intermediate bearing or support, clearly marked as a structural—not direct bearing—measurement;
- one foundation or support point when transmitted vibration is suspected.
At each point, define horizontal, vertical, and axial directions where the structure and access permit. Do not place a sensor on a rotating shaft, coupling, thin cover, removable guard, flexible conduit, or unsupported casing panel. A magnetic mount also requires a clean, flat, compatible surface; use the instrument manufacturer’s mounting method.
For every reading, store the screw output RPM, motor or gearbox input RPM, material rate, upstream level, current or estimated torque, VFD frequency, direction, temperature, and whether the casing is empty or loaded. Variable-speed machines need measurements at defined operating points rather than one mixed trend.
Choose the measurement that answers the question
No single unit covers every failure mode. SKF’s condition-monitoring manual describes overall velocity as a general-purpose measurement for low- to mid-frequency problems such as imbalance, looseness, misalignment, and shaft bow. It treats enveloped acceleration as a separate tool for low-amplitude repetitive impacts associated with rolling bearings and gears.
Use the measurements this way:
| Measurement | Best use | Important limitation |
|---|---|---|
| Overall velocity, usually RMS | General severity and trend of rotating machinery | Can miss early bearing impacts and cannot identify the cause alone |
| Acceleration or enveloped acceleration | Bearing, gear, or impact-type changes | Requires consistent bandwidth, sensor, and alarm method |
| FFT spectrum | Compare peaks with running speed, harmonics, gear mesh, and bearing frequencies | A matching peak is evidence to investigate, not proof |
| Phase, where competent analysis is available | Separate some alignment, looseness, and balance patterns | Requires suitable instrumentation and repeatable references |
| Temperature, current, and speed | Corroborate load, friction, slip, or loss of motion | Each can change for unrelated process or ambient reasons |
The SKF spectrum analysis guide recommends comparing spectra and overall values with prior readings under consistent conditions. It also warns that a bearing defect is often the result of another problem, including lubrication, contamination, misalignment, excessive load, installation, fit, or electrical current. Replacing the bearing without correcting the initiating fault invites recurrence.
Convert shaft speeds into diagnostic orders
Frequency analysis becomes useful only after each rotating speed is identified. Convert RPM to hertz with:
Rotational frequency (Hz) = RPM ÷ 60
Consider a hypothetical conveyor with a screw output speed of 60 rpm and a measured motor speed of 1,450 rpm:
- screw 1× frequency = 60 ÷ 60 = 1.0 Hz;
- motor 1× frequency = 1,450 ÷ 60 = 24.17 Hz.
A peak near 1 Hz that rises with cement load may direct attention toward the screw, output shaft, material buildup, intermittent contact, or load variation. A peak near 24.17 Hz measured strongly at the motor bearings may direct attention toward the motor or input side. Neither observation establishes the root cause. Actual motor slip, VFD speed, reducer ratio, gear tooth counts, bearing geometry, structural resonance, and sensor bandwidth must be known.
Do not label every 1× peak “imbalance” or every 2× peak “misalignment.” The SKF guide shows that running-speed harmonics, phase, direction, support stiffness, nearby machinery, and historical behavior all affect interpretation. A bent screw, loose support, rubbing flight, damaged coupling, and resonant structure can produce overlapping symptoms.
Use magnitude and change without inventing a limit
ISO 20816-1 provides general procedures for evaluating machine vibration using magnitude and change for operational monitoring and acceptance. It also states that measurement quantities and methods must be defined with their limitations. ISO 20816-3 includes conveyors within its stated scope for certain coupled industrial machines above 15 kW and operating between 120 and 30,000 rpm, while noting that machine-specific features can make general values inappropriate.
Those scope conditions matter. The screw output may run below 120 rpm even when its four-pole motor runs near 1,450 rpm. The motor, gearbox, and screw assembly may therefore need different applicable criteria. Do not copy a velocity chart from the internet and assign it to every point on the conveyor.
A change calculation can still make a trend visible. If a gearbox-output point measured 2.0 mm/s RMS at the documented baseline condition and later measures 3.2 mm/s under the same conditions:
Change = (3.2 − 2.0) ÷ 2.0 × 100% = 60%
This example shows a 60% increase; it does not declare 3.2 mm/s acceptable or unacceptable. Review the applicable standard or manufacturer limit, spectra, adjacent points, measurement uncertainty, and process data. Repeat the reading to exclude a bad mount or transient before deciding whether to continue, plan repair, or stop.
Define commissioning and operating alarms from:
- applicable manufacturer and standard limits at each component;
- a healthy installed baseline after alignment and loaded commissioning;
- magnitude and change criteria agreed by the owner and supplier;
- warning and trip actions, including confirmation delays where safe;
- the exact quantity, bandwidth, units, sensor, mounting, direction, speed, and load state.
Follow a fault-isolation sequence
Use symptoms to choose checks, not to announce a diagnosis:
| Evidence pattern | Plausible causes to investigate | Next safe check |
|---|---|---|
| Sudden broadband rise with impact noise or current spike | Foreign object, broken bearing, flight contact, loose or failed component | Stop, isolate, control stored material, and inspect using the approved procedure |
| High vibration at motor and gearbox input but lower at output | Motor, coupling, input alignment, soft foot, or local support | Compare radial and axial points; review alignment, fasteners, and motor condition |
| High output-side vibration that changes with screw load | Output bearing, bent shaft, buildup, screw contact, unstable feed, or overload | Compare empty and controlled-load data; inspect only after isolation |
| Harmonics of running speed and loose structural motion | Mechanical looseness, cracked support, poor fit, or rubbing | Check marked fasteners, feet, grout, welds, and casing clearance |
| Rising enveloped acceleration with modest overall velocity | Developing rolling-bearing or gear impacts | Confirm sensor setup and frequencies; review lubrication, load, alignment, and component data |
| Similar vibration when the conveyor is stopped but nearby plant runs | Transmitted vibration or structural resonance | Measure the support and adjacent machines under a controlled operating matrix |
The cement screw conveyor installation guide covers support, centerline, assembly, and alignment hold points. For intermediate support evidence, the hanger-bearing selection and maintenance guide explains lubrication, journal, access, and alignment boundaries. If vibration coincides with a restriction or stall, follow the blockage diagnostic sequence rather than repeatedly resetting the drive.
After repair, repeat the same route at the same operating points. Record the as-left alignment, fastener status, component changes, spectra, overall values, temperature, current, speed, and material rate. A repair is not closed merely because the sound appears quieter.
Conclusion
Cement screw conveyor vibration troubleshooting works when the measurement is repeatable and the process condition is recorded. Start with safe triage, measure stationary bearing and gearbox housings at defined directions, separate motor, gearbox, and screw speeds, and compare overall velocity, enveloped acceleration, spectra, current, and temperature with a healthy baseline. Use ISO or manufacturer criteria only within their stated scope, and treat frequency patterns as clues that require confirmation—not automatic diagnoses.
For a project review, send VOGO the layout, duty, speeds, motor and reducer data, support arrangement, measurement route, baseline readings, spectra, and operating condition.